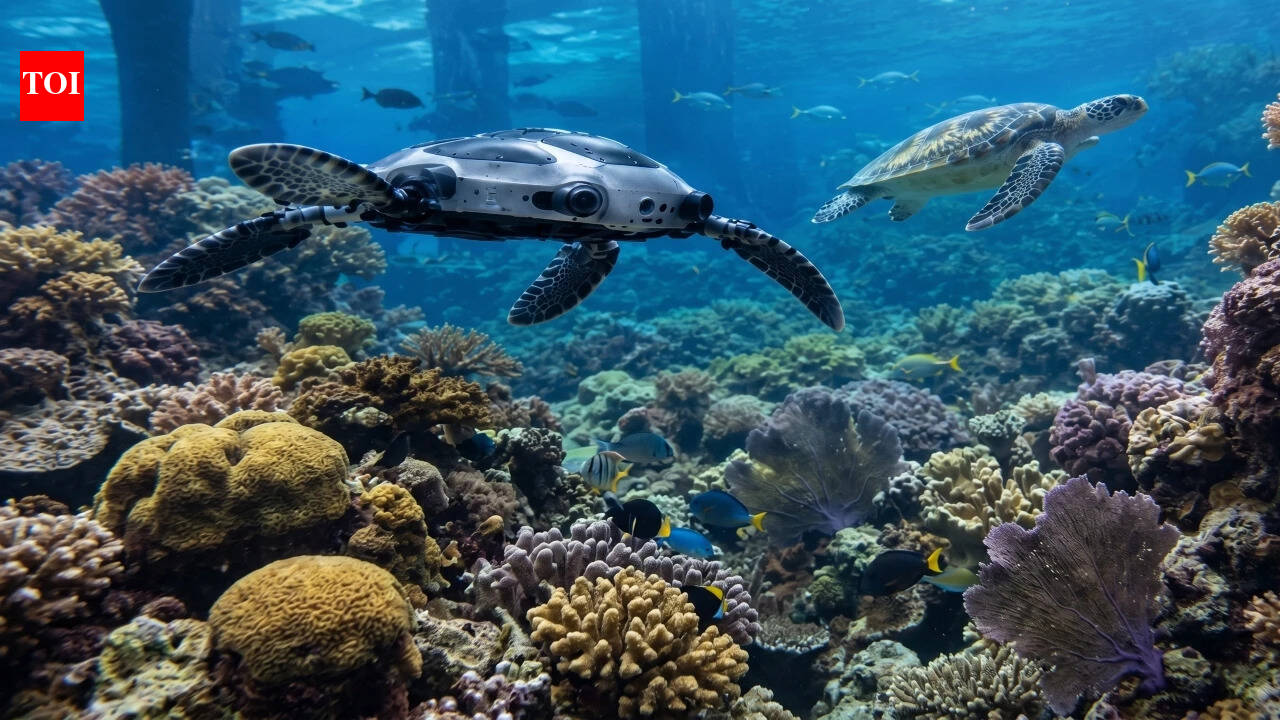
Researchers at the Massachusetts Institute of Technology have developed an autonomous underwater robot named Crush, designed to mimic the shape and movement of a juvenile hawksbill sea turtle to monitor fragile marine ecosystems safely. Tested inside a coral reef exhibit at the New England Aquarium in Boston, the soft-flippered machine successfully avoided obstacles in 91 percent of untethered trials while swimming alongside real marine life, offering a potential new tool for observing delicate habitats without causing physical damage.
Why Bioinspired Design Matters for Coral Reefs
Standard underwater vehicles rely on stiff propellers and thrusters that work efficiently in open water but pose significant risks in tight coral formations. A rigid vessel can break fragile coral branches in seconds if it misjudges distance. In contrast, Crush uses flexible flippers that replicate a turtle’s gentle swimming motion, allowing the robot to travel at turtle-like speeds and drastically reducing the likelihood of permanent ecological damage.
The engineering team aimed to bridge the gap between organic movement and autonomous decision-making. While traditional marine research vehicles are often bulky and difficult to maneuver in crowded environments, Crush blends soft robotics with onboard cameras and visual processing to move through complex spaces independently.
Real-World Testing at the New England Aquarium
Rather than depending strictly on computer simulations or empty laboratory pools, the developers conducted extended tests in a living aquarium display containing real coral and marine animals, including a 550-pound green sea turtle, barracudas, and stingrays. During twenty separate tracking trials, the robot used its onboard vision systems to track these creatures in real time, altering its heading as the animals darted or paused unexpectedly.

Crucially, the resident marine animals displayed no clear behavioral changes when the robot swam near them. Researchers point to this lack of behavioral disruption as early proof that the design can operate closely with wildlife without causing undue stress.
Tackling Global Conservation Challenges
Coral reefs worldwide face mounting pressures from warming oceans, pollution, and physical degradation. Organizations like the National Oceanic and Atmospheric Administration rely on consistent, long-term data collection to track reef decline. Traditional monitoring usually requires frequent diver visits or bulky submersibles that are unsuited for close-range operations.
A soft-bodied, turtle-inspired robot could eventually support large-scale monitoring in fragile marine terrain at a level that human divers cannot easily sustain. The controlled environment of an aquarium provided a realistic testing ground, allowing engineers to evaluate the system without the logistical and ecological risks inherent in open-ocean deployment.
Path Forward for Wild Reef Deployment
Despite a strong 91 percent success rate in avoiding obstructions during aquarium trials, Crush remains a research prototype rather than a deployment-ready instrument. The remaining nine percent margin—representing occasional contact with obstacles—indicates that developers must significantly tighten accuracy before deploying autonomous systems near wild, living reef systems.
Related reading